> For the complete documentation index, see [llms.txt](https://doc.realvirtual.io/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://doc.realvirtual.io/extensions/modelzoo/wandelbots-nova-fanuc-crx.md).
# Wandelbots Nova Fanuc CRX
This ModelZoo scene demonstrates the integration of a **Wandelbots NOVA** controlled robot in a virtual commissioning environment using **realvirtual.io**.
The robot model used in this scene is a **Fanuc CRX-10iA/L**. All PLC logic for the **entry and exit conveyors** is handled **entirely inside the simulation**, so no external PLC is needed.
To use this model, make sure you have:
* Access to **Wandelbots NOVA** (cloud or local installation)
* The robot controller configured for the **Fanuc CRX-10iA/L**
## Interface Configuration
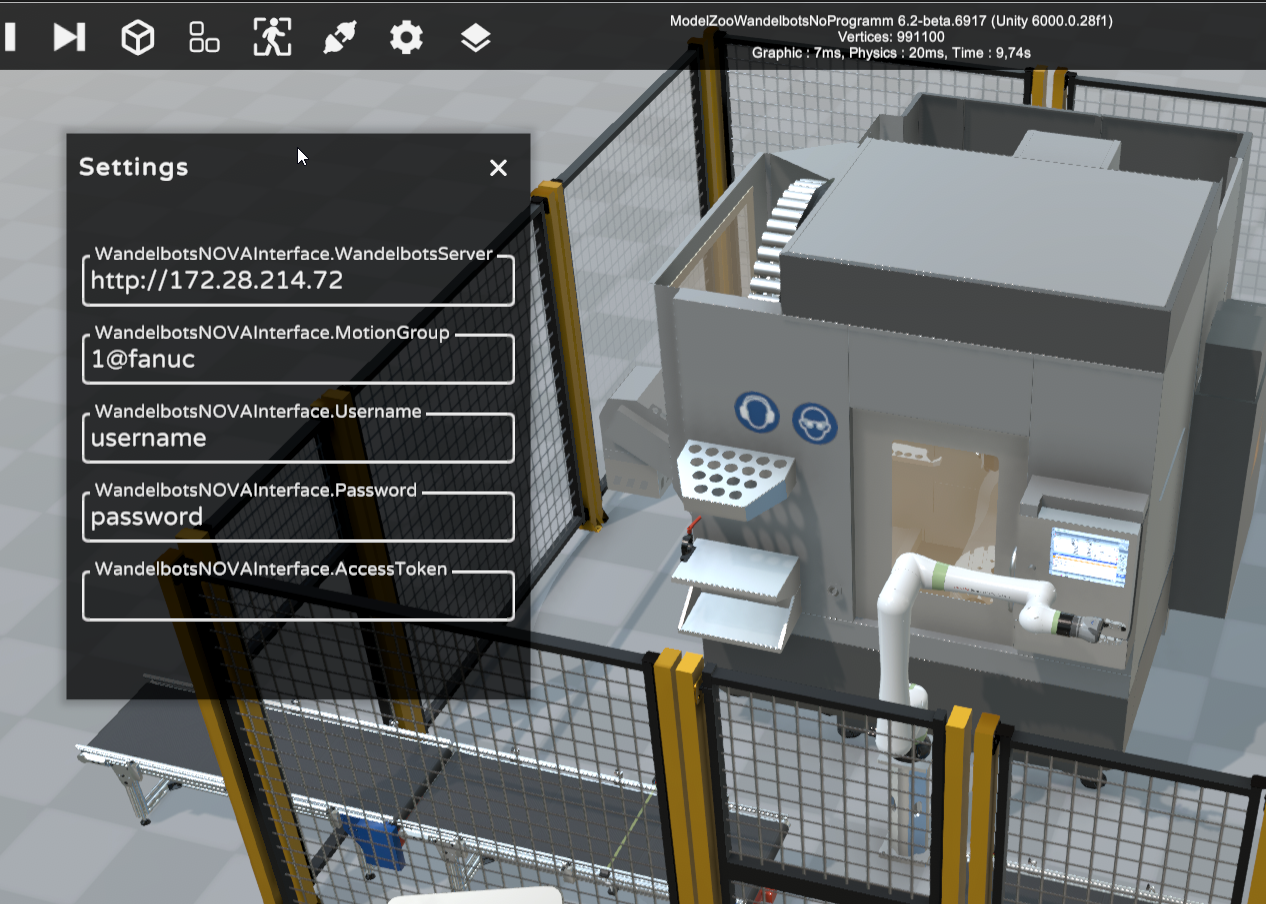
To connect the simulation with a [**Wandelbots NOVA** ](https://www.wandelbots.com/de)instance, the following parameters must be set. Open the **⚙️ Settings** window in the top menu bar to access these fields:
| Field | Description |
| ------------------------------------------ | --------------------------------------------------------------------------------- |
| `WandelbotsNOVAInterface.WandelbotsServer` | IP address or URL of your Wandelbots NOVA server (e.g. `http://172.28.214.72`) |
| `WandelbotsNOVAInterface.MotionGroup` | The motion group identifier for the robot (e.g. `1@fanuc` for a Fanuc CRX-10iA/L) |
| `WandelbotsNOVAInterface.Username` | Username for NOVA login |
| `WandelbotsNOVAInterface.Password` | Password for NOVA login |
| `WandelbotsNOVAInterface.AccessToken` | *Optional:* Only required when connecting to a **cloud-hosted** NOVA instance |
After entering your connection data, activate the interface using the **🔌 connect switch** in the menu bar. Once the connection is active, the plug icon will turn green.
> 💡 Note: The **Access Token** is not needed for local or offline installations—only for authenticated access to the cloud-based NOVA server.
Wandelbots NOVA interface configuration
## Signal Mapping
The following digital signals are used for handshaking between **realvirtual.io** and the **Wandelbots NOVA** robot:
### **Inputs (realvirtual.io → NOVA)**
| Signal | Type | Description |
| ------ | ----- | -------------------------------------- |
| `di1` | Input | Load Cell – triggers robot to load |
| `di2` | Input | Unload Cell – triggers robot to unload |
| `di3` | Input | Gripper Closed – gripper status |
### **Outputs (NOVA → realvirtual.io)**
| Signal | Type | Description |
| ------ | ------ | ------------------------------------------------ |
| `do1` | Output | Robot Is Loading – robot has started loading |
| `do2` | Output | Robot Is Unloading – robot has started unloading |
| `do3` | Output | Close Gripper – command to close gripper |
***
#### Robot Programming
The robot behavior must be programmed in **Wandelbots NOVA**.\
Use the signal mapping above to define your automation logic and synchronize the robot with the simulation scene.
{% hint style="warning" %}
This page is under construction!
{% endhint %}
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://doc.realvirtual.io/extensions/modelzoo/wandelbots-nova-fanuc-crx.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.